1. Introduction
Looking at a photograph of a corridor or a receding road is enough to perceive depth: parallel lines seem to converge toward a distant point, objects seem to shrink with distance. This familiar experience is the result of a precise geometric projection — linear perspective — and sophisticated brain processing of depth cues. This article examines the geometry of perspective, its curvilinear extensions, and the question of whether and when spirals actually appear in these projections.
2. Linear Perspective: Geometry and History
Linear perspective is a projection method that represents a three-dimensional space on a two-dimensional surface by simulating how a single eye perceives the world from a fixed viewpoint. Its geometric principle is simple: all light rays from the scene pass through a single point (the center of projection, or eye) before reaching the image plane. Lines in space that are not parallel to the image plane project as lines that converge toward a vanishing point.
The mathematical codification of linear perspective is attributed to Filippo Brunelleschi around 1413–1420, in Florence. Leon Battista Alberti provided the first systematic theoretical description in his treatise <em>De Pictura</em> (1435). Piero della Francesca developed a more rigorous mathematical theory in <em>De Prospectiva Pingendi</em> (c. 1474). These works transformed pictorial representation in Europe and laid the foundations of projective geometry, mathematically formalized by Gérard Desargues in the seventeenth century.
The number of vanishing points depends on the number of principal directions in the scene that are not parallel to the image plane. A one-point perspective (frontal view of a corridor) has a single central vanishing point. A two-point perspective (corner view of a building) has two vanishing points on the horizon line. A three-point perspective (bird's-eye or worm's-eye view of a building) has three vanishing points. In all these cases, lines converge toward points, not toward spirals.
Projective Geometry and Points at Infinity Projective geometry formalizes perspective by adding points at infinity to the Euclidean plane. In this framework, two parallel lines meet at a point at infinity (their common vanishing point). The projective plane is the Euclidean plane augmented by a line at infinity (the horizon). Perspective projection is then a projective transformation, which preserves incidence (points on a line remain on a line) but not distances or angles. This property explains why parallel lines project as converging lines: they meet at their common point at infinity, which projects to a finite point on the image plane.
3. Curvilinear Perspectives: Projections and Distortions

Classical linear perspective works well for limited fields of view (approximately 60°), but produces significant distortions for wider angles. A spherical object photographed with a wide angle appears elliptical near the edges of the image. Curvilinear perspectives are alternatives that distribute the directions of space differently on the image plane, using non-linear projections.
The fisheye (or equidistant) projection maps angular directions proportionally to their angle from the optical axis. It can cover a field of view of 180° or more. In this projection, lines in space that pass through the center of the image remain straight, but others become curves. The shape of these curves depends on the direction of the line in space and its distance from the optical axis.
Spherical (or stereographic) projection maps the visual sphere onto a plane using a projection from one pole of the sphere. It preserves local angles (conformal projection) but distorts distances. In this projection, circles on the sphere project as circles or lines on the plane. Lines in space project as circular arcs.
In none of these common projections do lines in space generally project as spirals. A line projects as a curve whose shape depends on the chosen projection, but this curve is typically a circular arc, a sinusoid, or a simple algebraic curve — not a spiral. A spiral implies a continuous variation of radius with angle, which does not correspond to the projection of a line in standard projection systems.
4. The Brain and the Construction of Depth
The perception of depth is not a direct reading of image geometry. The brain uses many cues, some monocular (available with one eye) and others binocular (requiring both eyes). Monocular cues include linear perspective, the relative size of known objects, occlusion (one object in front of another), texture gradients (a textured surface appears finer with distance), shading, and atmospheric perspective (distant objects appear bluer and less contrasted).
The main binocular cue is retinal disparity: the two eyes see the world from slightly different positions, and the brain uses the difference between the two images to calculate the distance of nearby objects (stereopsis). This cue is effective up to about 6 meters; beyond that, the disparity becomes too small to be useful.
The brain combines these cues through a probabilistic inference process. When cues are consistent, depth perception is robust and accurate. When they conflict (as in certain optical illusions or virtual reality images), the brain must resolve a conflict and may produce unstable or erroneous perceptions. This combination of cues explains why a linear perspective image, even on a flat surface, can give a strong impression of depth.
5. The Spiral in Artistic Composition
If the spiral is not the fundamental geometry of perspective, it appears frequently in artistic composition as a tool for guiding the gaze. The compositional spiral (sometimes called the golden spiral or Fibonacci spiral, though these terms are often used loosely) is a curve that guides the viewer's eye from the edges of the image toward a central focal point. It is used in photography, painting, and graphic design as a compositional principle.
Famous examples include Raphael's <em>The Nativity</em>, Michelangelo's <em>The Creation of Adam</em>, and many landscape photographs. In these works, the spiral is not a geometric property of the projection; it is a deliberate organization of compositional elements to create visual movement. The compositional lines (horizons, diagonals, curves) are arranged to form an implicit spiral that attracts and holds the gaze.
It is important to distinguish the compositional spiral (a deliberate tool of the artist) from the geometric spiral (a mathematical property of the projection). The former is an artistic convention whose effectiveness rests on properties of human visual perception; the latter would be an intrinsic property of the projection system, which it generally is not.
6. Convergence and Spiral: Two Distinct Geometries
Perspective convergence and the spiral are two distinct geometric phenomena that can coexist in an image but do not derive from each other. Perspective convergence is the projection of parallel lines toward a vanishing point; it is a property of central projection (linear perspective) and does not produce a spiral. The spiral is a curve whose radius varies with angle; it can be constructed artistically or appear in particular compositions, but it is not the natural result of a perspective projection.
An image can contain both strong perspective convergence (lines converging toward a vanishing point) and a spiral composition (elements organized in a spiral). These two properties are independent. An image can have one without the other, or both together. Confusion between the two is common in popular descriptions of perspective, but it is not geometrically justified.
What perspective brings to the "Spirals Everywhere" project is an illustration of convergence as a general geometric phenomenon. The convergence of parallel lines toward a vanishing point is a property of central projection that appears in vision, photography, and painting. It shares with the spiral the property of directing the gaze toward a focal point, but through a different geometric mechanism. Distinguishing between the two enriches the understanding of each.
Perspective begins with division by depth
Place the projection center at the origin and a point in front at (X,Y,Z), with Z>0. Under our virtual image-plane convention, image coordinates are x=fX/Z and y=fY/Z. Similar triangles explain the formula: equally tall objects appear different in size at different depths. Doubling Z halves projected size; doubling f doubles it without moving the object. [1]
The first graph follows a segment of height H=1 in model units. The slider changes focal length. The depth curve is a hyperbola, not a spiral. This separates a precise geometric cause from a visual impression. Real photographs also require principal-point coordinates, sensor dimensions and distortion calibration; these are deliberately omitted here to isolate division by Z.
A vanishing point is not a winding center
Our abstract road has edges at X=−1 and X=+1 at constant height. As Z increases, projected horizontal positions approach zero and crossbars become closer. Parallel world lines thus converge in the image toward the same direction at infinity. Neither edge rotates around the vanishing point. Perspective convergence is neither physical attraction nor a logarithmic spiral.
The sketch shows an ideal ground plane with no camera tilt. Crossbars are assigned depths and projected using the same law, rather than spaced by hand to create the effect. Other families of parallel lines have other vanishing points. Analyzing a drawing therefore requires identifying the relevant direction family before claiming that one center organizes the whole scene.
A wide-angle lens changes the projection law
An ideal rectilinear projection places a ray at angle θ a distance r=f tan θ from the center. Distance grows rapidly as θ approaches 90 degrees. An ideal equidistant projection uses r=fθ with θ in radians, compressing peripheral angles more strongly. OpenCV fisheye models add calibration coefficients to this angular relation. Our comparison sets those coefficients to zero and does not represent every real fisheye lens. [1]
Architectural curvature in an image can therefore arise from projection rather than object shape. An artist can also construct curvilinear perspective without exactly imitating a lens. Comparing images requires viewpoint, field of view and transformation. Overlaying a spiral on a photograph cannot identify that transformation; several independent scene points or lines must be checked.
A case where projection really produces a spiral
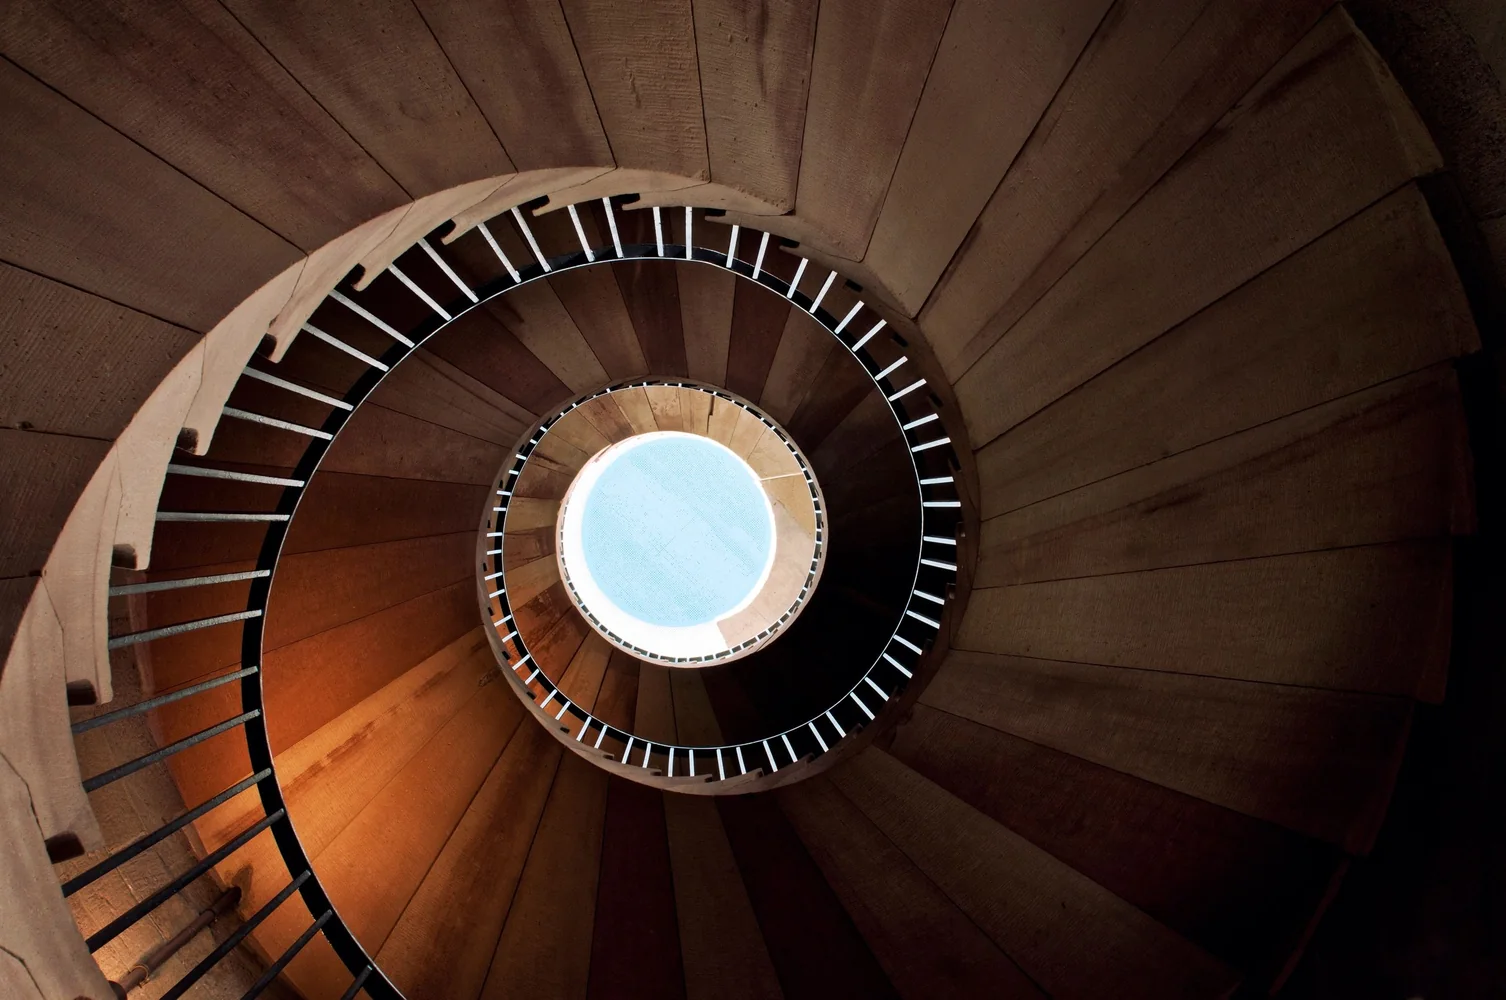
Construct a spatial helix: X=cos t, Y=sin t and Z=2+0.3t. Its radius about Z stays one while depth increases steadily. Seen from the side, it oscillates without shrinking. Viewed along its axis with focal length one, its image radius becomes 1/(2+0.3t). Each turn is smaller than the previous one. The planar spiral results from increasing depth, not a shrinking radius of the actual helix.
Both views represent the same five hundred parameter intervals across three turns. The planar curve is not logarithmic: radius varies as the reciprocal of an affine function of angle, not an exponential. Moving the camera off-axis would change it again. This provides a checkable method: define the three-dimensional object, state the projection, compute its points and only then name the resulting figure.
References
- [1]OpenCV. (s.d.). Fisheye camera model — OpenCV 4.13.0 documentation. https://docs.opencv.org/4.13.0/db/d58/group__calib3d__fisheye.html [accessed 2026-10-19]